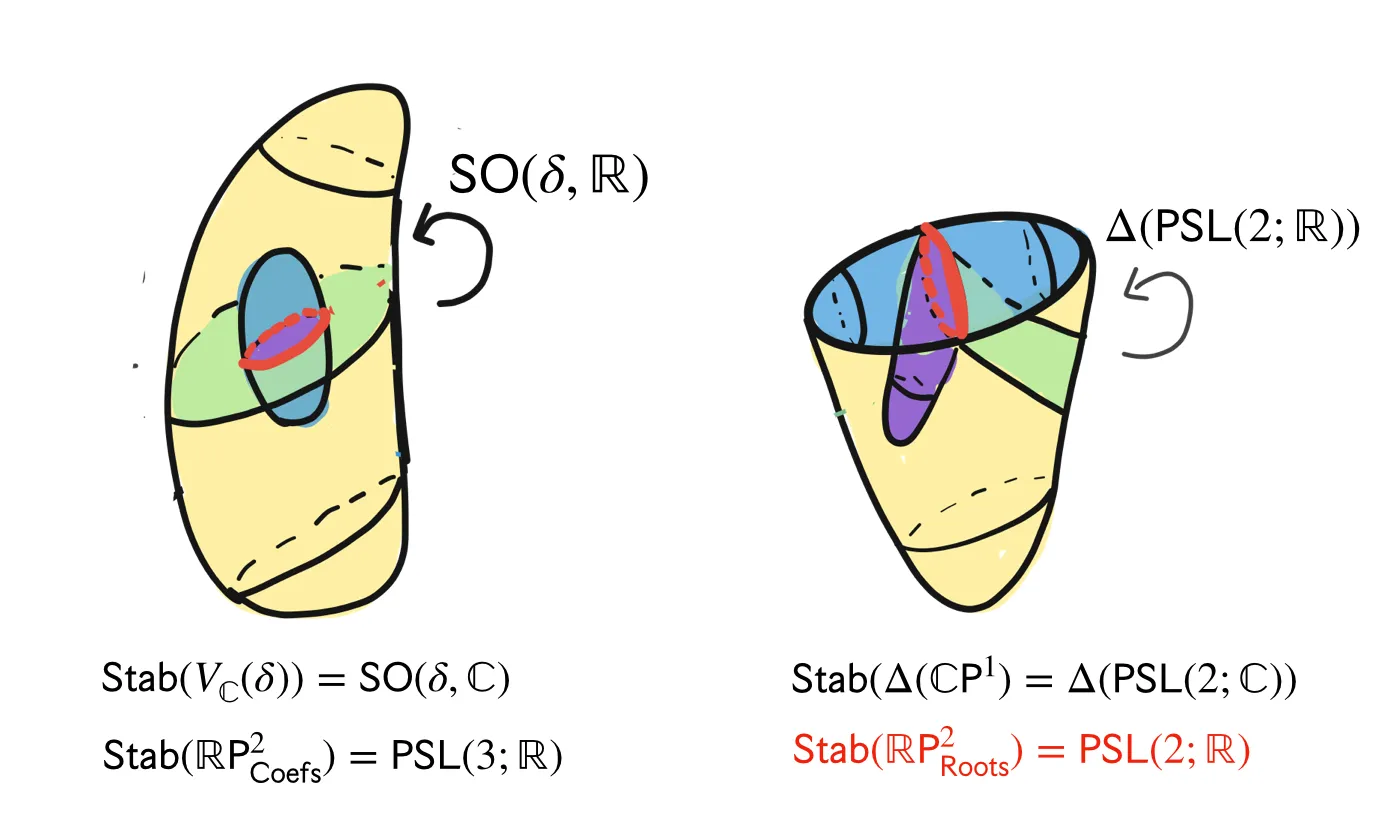
The quadratic formula as an isometry between models of the hyperbolic plane.
We study the quadratic formula ( − b ± b 2 − 4 a c ) / 2 a \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\left(-b\pm\sqrt{b^2-4ac}\right)/2a ( − b ± b 2 − 4 a c ) /2 a ≤ 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
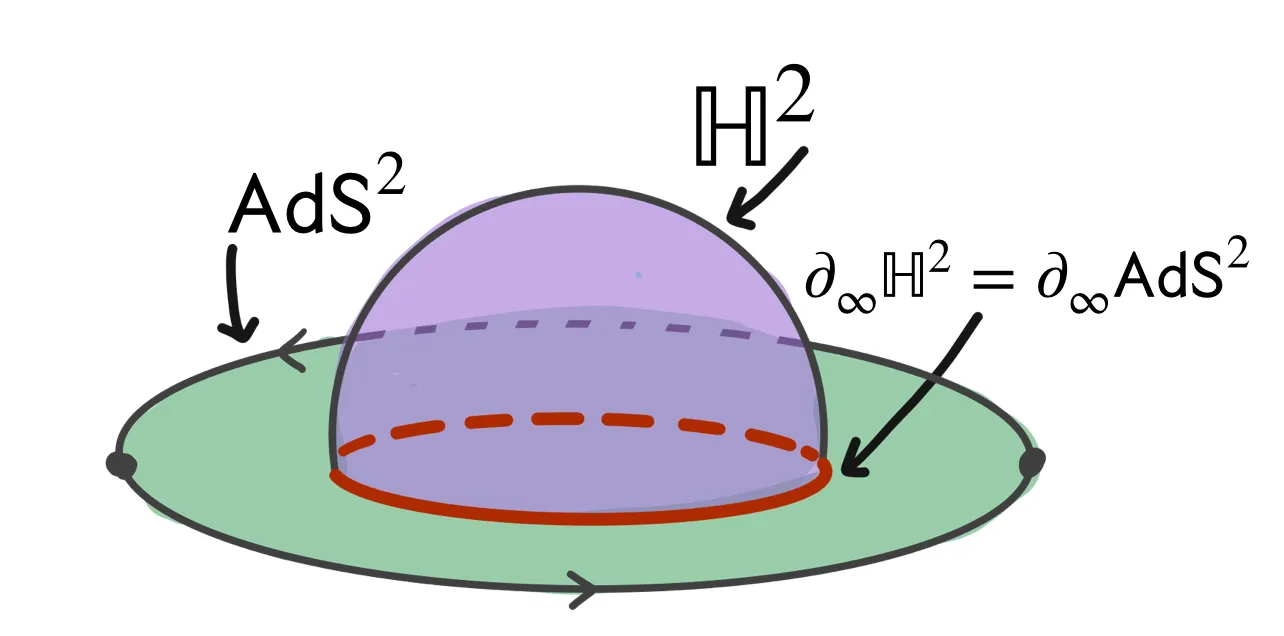
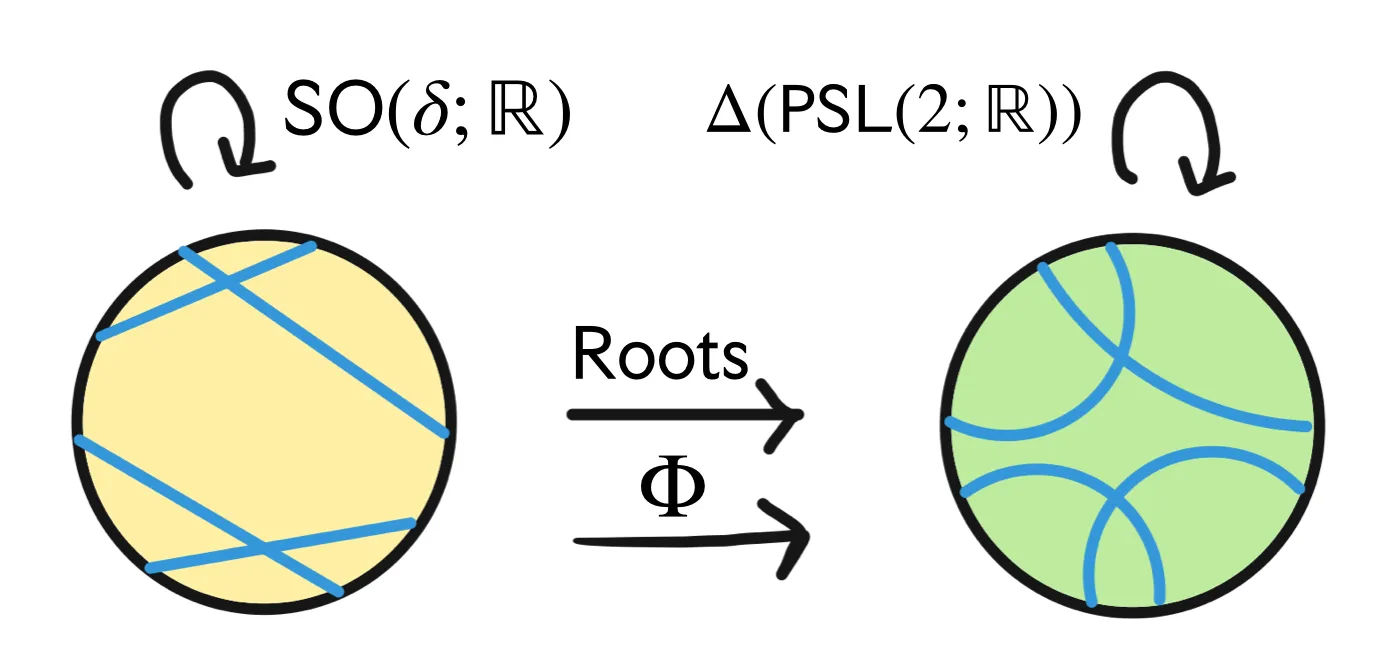
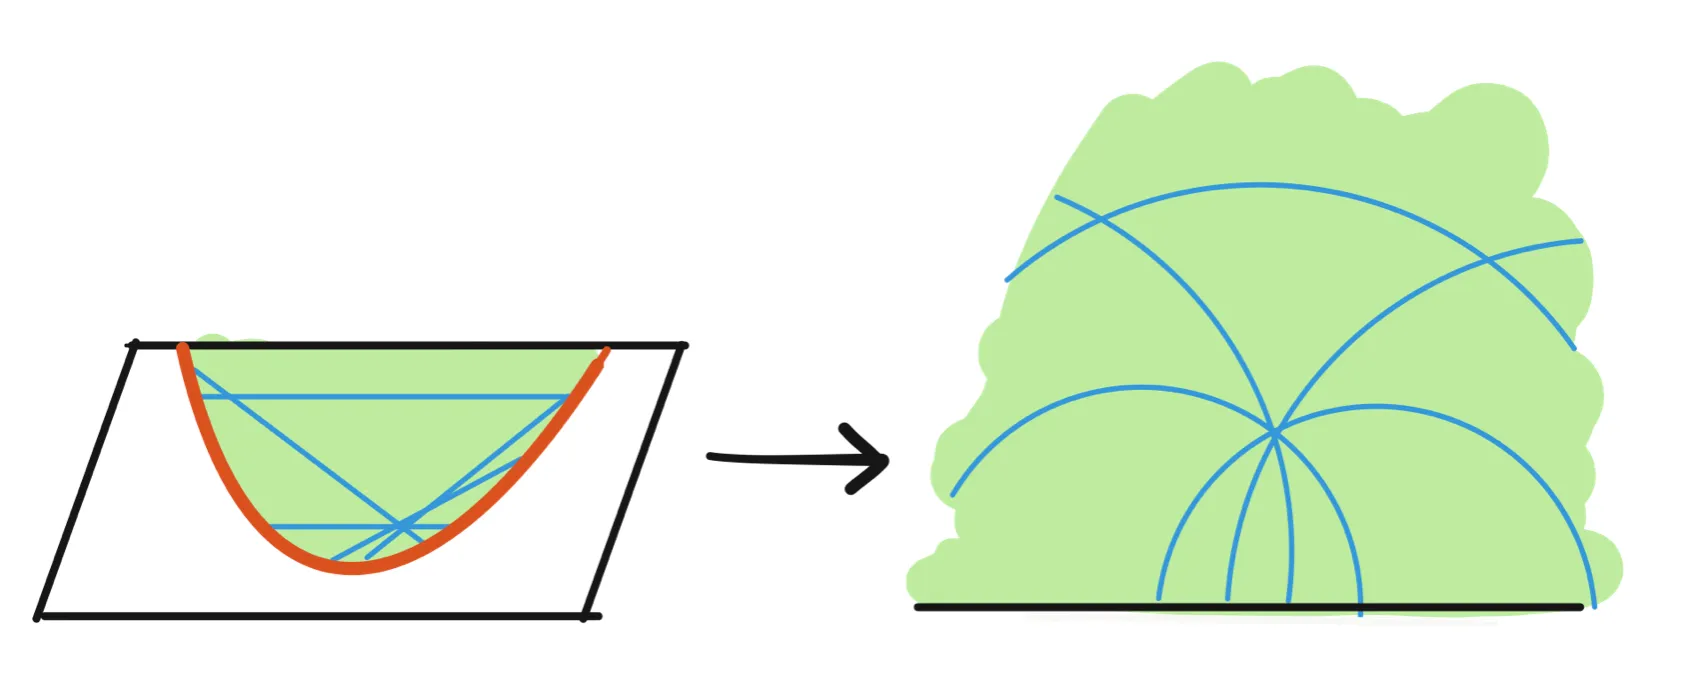
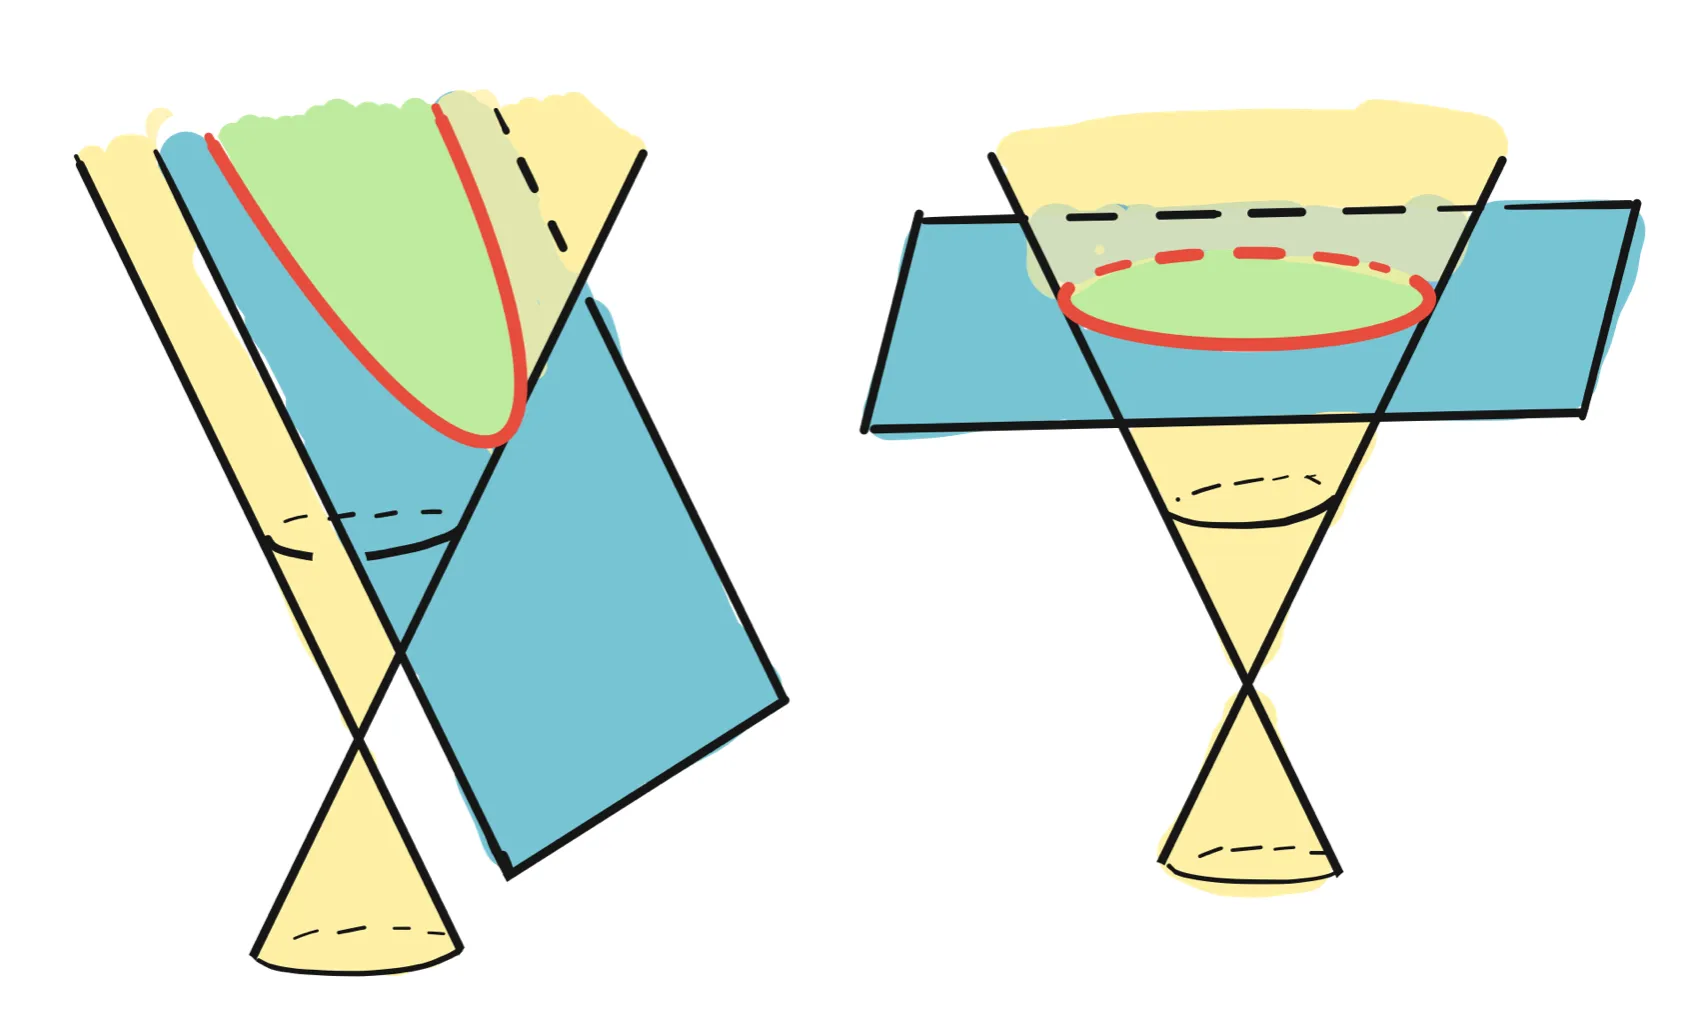
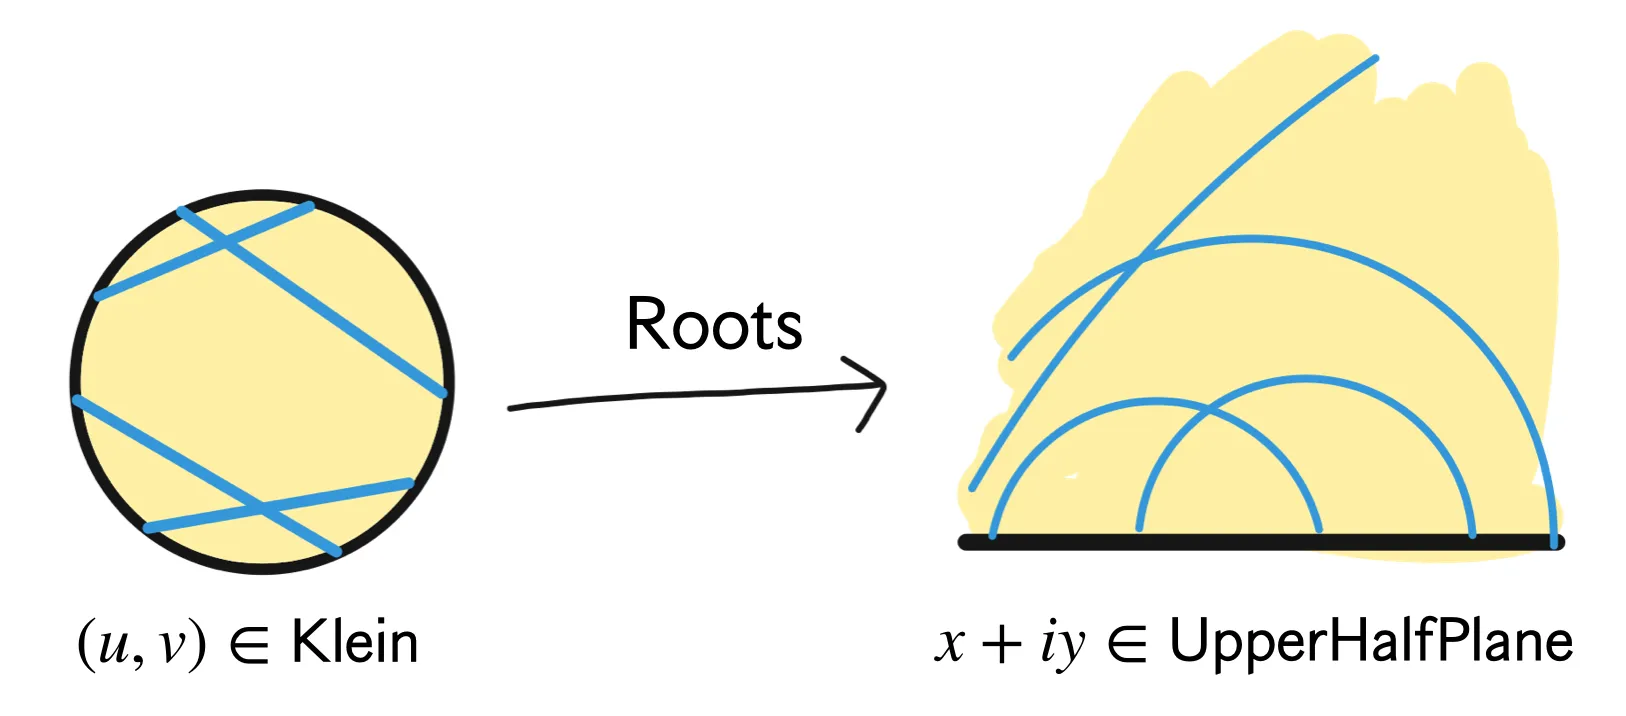
\leq 2 ≤ 2 quadratic formula realizes an isometry from the projective model to the conformal model of the hyperbolic plane.
Geometry of the map Polynomials ⟶ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\longrightarrow ⟶
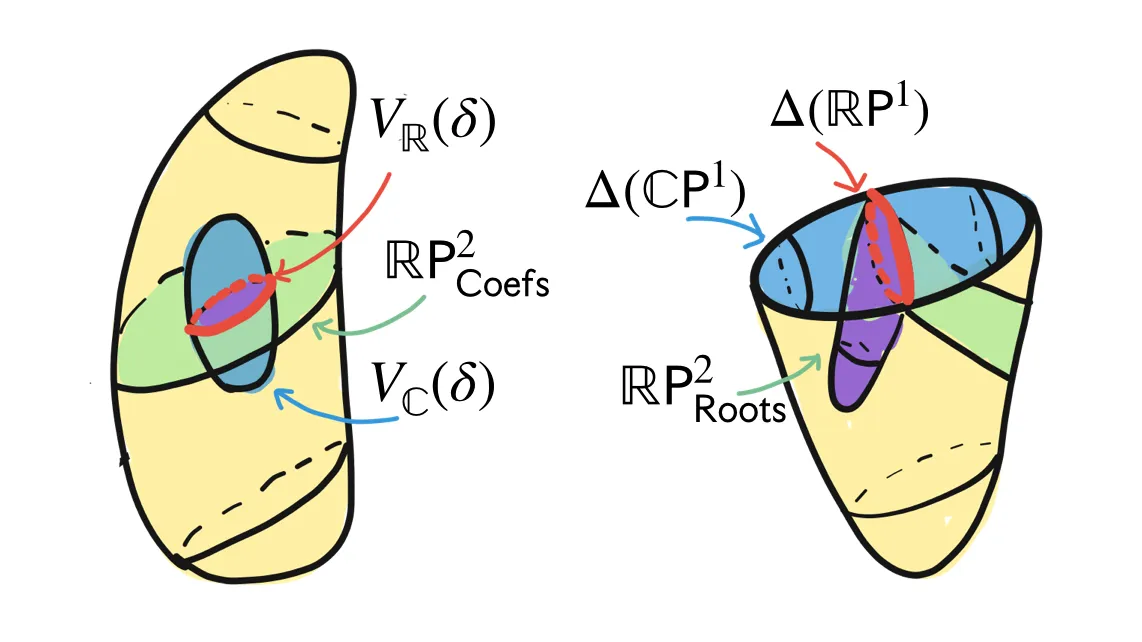
Our goal is to understand in detail the geometry of the quadratic formula as a map from coefficients to roots, and from this understanding extract a cool fact: namely that restricted to real coefficients, the relevant geometry includes both a projective and a conformal model of the hyperbolic plane.
Here we start the road to viewing the relationship between a polynomial and its roots as a geometric problem by first casting it as a topological one.
As our interest lies in the quadratics everything is quite explicit: however just here at the beginning I will talk about general n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
n n
The fundamental theorem of algebra guarantees every complex nonconstant polynomial has at least one root, or equivalently
every degree n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
n n n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
n n R o o t s : P o l y n o m i a l s ↦ T h e i r R o o t s \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots:Polynomials\mapsto Their\;Roots Roots : P o l y n o mia l s ↦ T h e i r R oo t s P o l n ≅ C × × C n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Pol_n\cong\C^\times\times\C^n Pol n ≅ C × × C n n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
n n C \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\C C f ∈ P o l n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
f\in\Pol_n f ∈ Pol n R o o t s ( f ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots(f) Roots ( f ) symmetric power : the n t h \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
n^{th} n t h X \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
X X n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
n n S P n ( X ) = X n / \Sym ( n ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^n(X)=X^n/\Sym(n) SP n ( X ) = X n / \Sym ( n ) R o o t s : C × C n → S P n ( C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots\colon\C^\times\C^n\to\SP^n(\C) Roots : C × C n → SP n ( C ) f \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
f f c f \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
cf c f
The n t h \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
n^{th} n t h C \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\C C n t h \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
n^{th} n t h C \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\C C R o o t s : C n → S P n ( C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots\colon \C^n\to\SP^n(\C) Roots : C n → SP n ( C )
This familiar setting is not quite where our story will take place however.
Instead of projectivizing the space C × × C n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\C^\times\times\C^n C × × C n n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
n n include back in the missing polynomials of lower degree, and study the space P o l ≤ n ≅ C n + 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Pol_{\leq n}\cong\C^{n+1} Pol ≤ n ≅ C n + 1 S P n ( C ) ∪ S P n − 1 ( C ) ∪ ⋯ ∪ S P 1 ( C ) ∪ S P 0 ( C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^n(\C)\cup \SP^{n-1}(\C)\cup\cdots\cup \SP^1(\C)\cup\SP^0(\C) SP n ( C ) ∪ SP n − 1 ( C ) ∪ ⋯ ∪ SP 1 ( C ) ∪ SP 0 ( C ) n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
n n X \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
X X X ∪ { ∞ } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
X\cup\{\infty\} X ∪ { ∞ } k < n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
k<n k < n k \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
k k { x 1 , … , x k } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\{x_1,\ldots, x_k\} { x 1 , … , x k } n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
n n { x 1 , … , x k , ∞ , … , ∞ } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\{x_1,\ldots, x_k, \infty,\ldots, \infty\} { x 1 , … , x k , ∞ , … , ∞ } ∞ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\infty ∞
For polynomials, this amounts to (for example) saying that, viewed in relation to cubic polynomials, a linear polynomial has two roots at infinity .
This is actually quite natural, as when we write down families of cubics which in the limit become linear, two of their roots escape all bounded sets in C \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\C C S P n ( C ) ∪ S P n − 1 ( C ) ∪ ⋯ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^n(\C)\cup\SP^{n-1}(\C)\cup\cdots SP n ( C ) ∪ SP n − 1 ( C ) ∪ ⋯ S P n ( C ∪ { ∞ } ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^n(\C\cup\{\infty\}) SP n ( C ∪ { ∞ }) R o o t s : P o l ≤ n → S P n ( C ∪ { ∞ } ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots\colon \Pol_{\leq n}\to\SP^n(\C\cup\{\infty\}) Roots : Pol ≤ n → SP n ( C ∪ { ∞ }) C P n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^{n} CP n S P n ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^n(\CP^1) SP n ( CP 1 )
The n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
n n 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
2 2 C P n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^n CP n R o o t s : C P n → S P n ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots\colon \CP^n\to \SP^n(\CP^1) Roots : CP n → SP n ( CP 1 )
As each space of lower degree polynomials is naturally built into the construction, we may take the direct limit of this over inclusions for increasing n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
n n
The infinite symmetric power of the 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
2 2 C P ∞ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^\infty CP ∞ R o o t s : P ( C [ z ] ) → S P ∞ ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots\colon \mathsf{P}(\C[z])\to \SP^\infty(\CP^1) Roots : P ( C [ z ]) → SP ∞ ( CP 1 )
What does this tell us?
Firstly, that there is a uniform, natural way to consider polynomials of lower degree as degenerations of higher degree polynomials, allowing us to union to domains, codomains and root maps for each lower degree into a single morphism C P n → S P n ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^n\to\SP^n(\CP^1) CP n → SP n ( CP 1 ) X ⊂ P o l ≤ n \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
X\subset \Pol_{\leq n} X ⊂ Pol ≤ n projective model P ( C o e f s ( X ) ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\mathsf{P}(\mathsf{Coefs}(X)) P ( Coefs ( X )) symmetric powers model R o o t s ( X ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\mathsf{Roots}(X) Roots ( X )
Quadratics
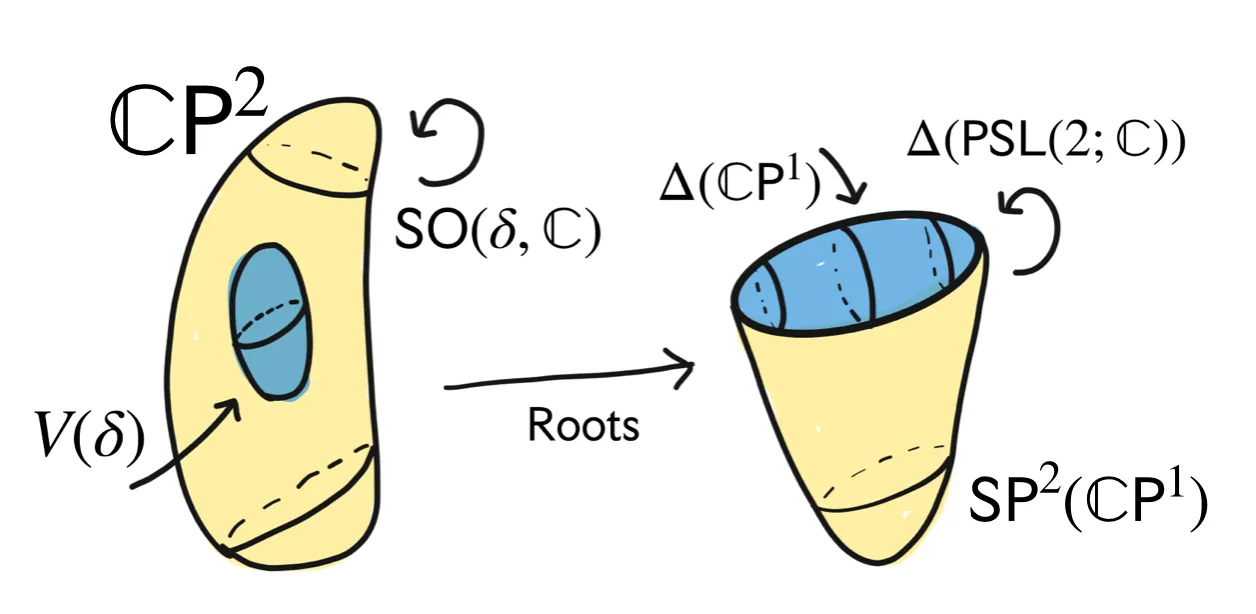
Restricting to (at most) quadratic polynomials, gives the map R o o t s : C P 2 → S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots\colon \CP^2\to\SP^2(\CP^1) Roots : CP 2 → SP 2 ( CP 1 ) [ a : b : c ] \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
[a:b:c] [ a : b : c ] { z , w } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\{z,w\} { z , w } f ( z ) = a z 2 + b z + c \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
f(z)=az^2+bz+c f ( z ) = a z 2 + b z + c δ ( f ) = b 2 − 4 a c \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\delta(f)=b^2-4ac δ ( f ) = b 2 − 4 a c
In this low degree, an explicit description of the second symmetric power of C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
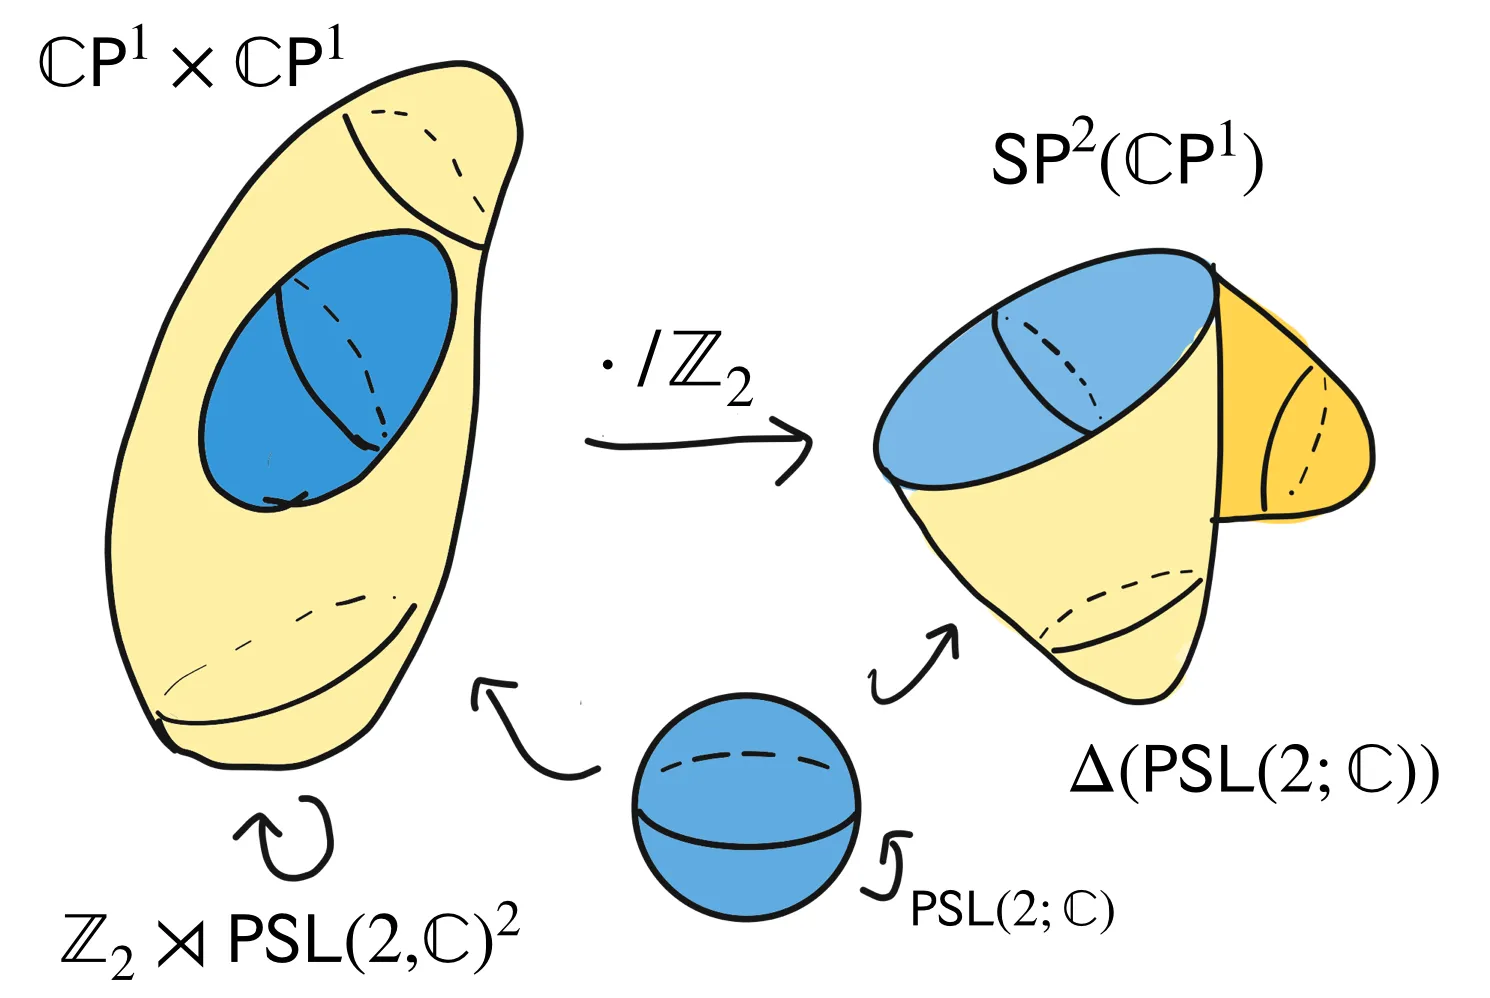
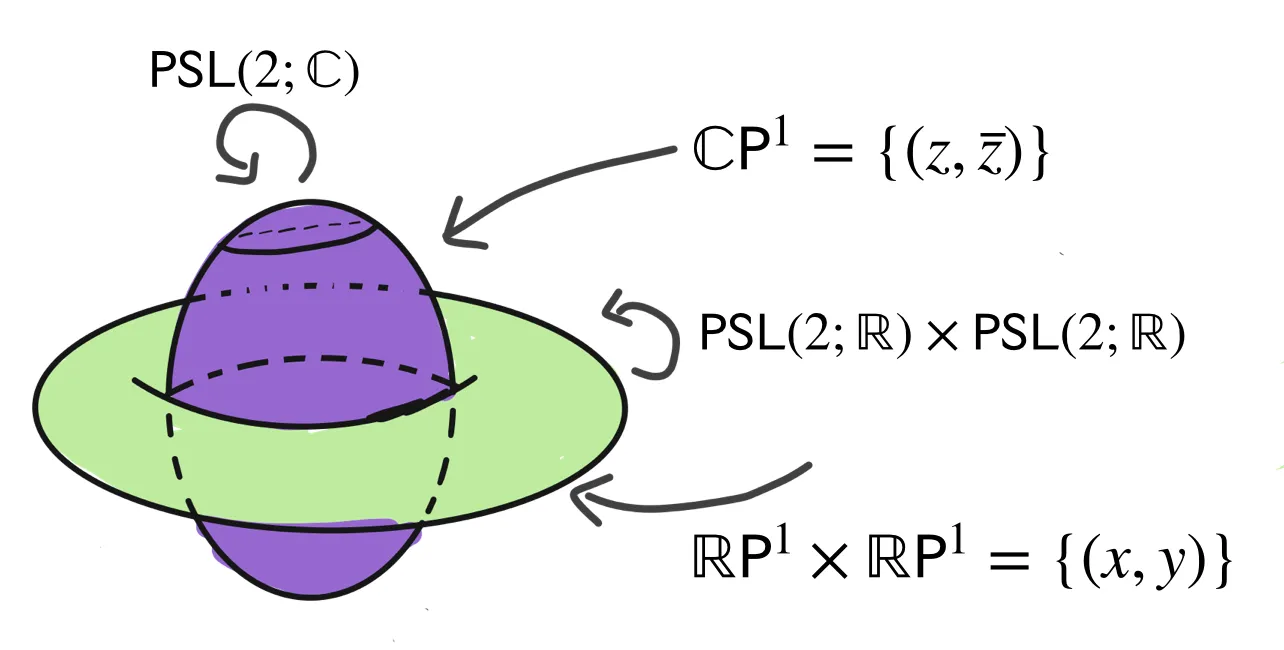
\CP^1 CP 1 S P 2 ( C P 1 ) = ( C P 1 × C P 1 ) / Z 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1)=(\CP^1\times \CP^1)/\Z_2 SP 2 ( CP 1 ) = ( CP 1 × CP 1 ) / Z 2 Z 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Z_2 Z 2 C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1 CP 1 R 3 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
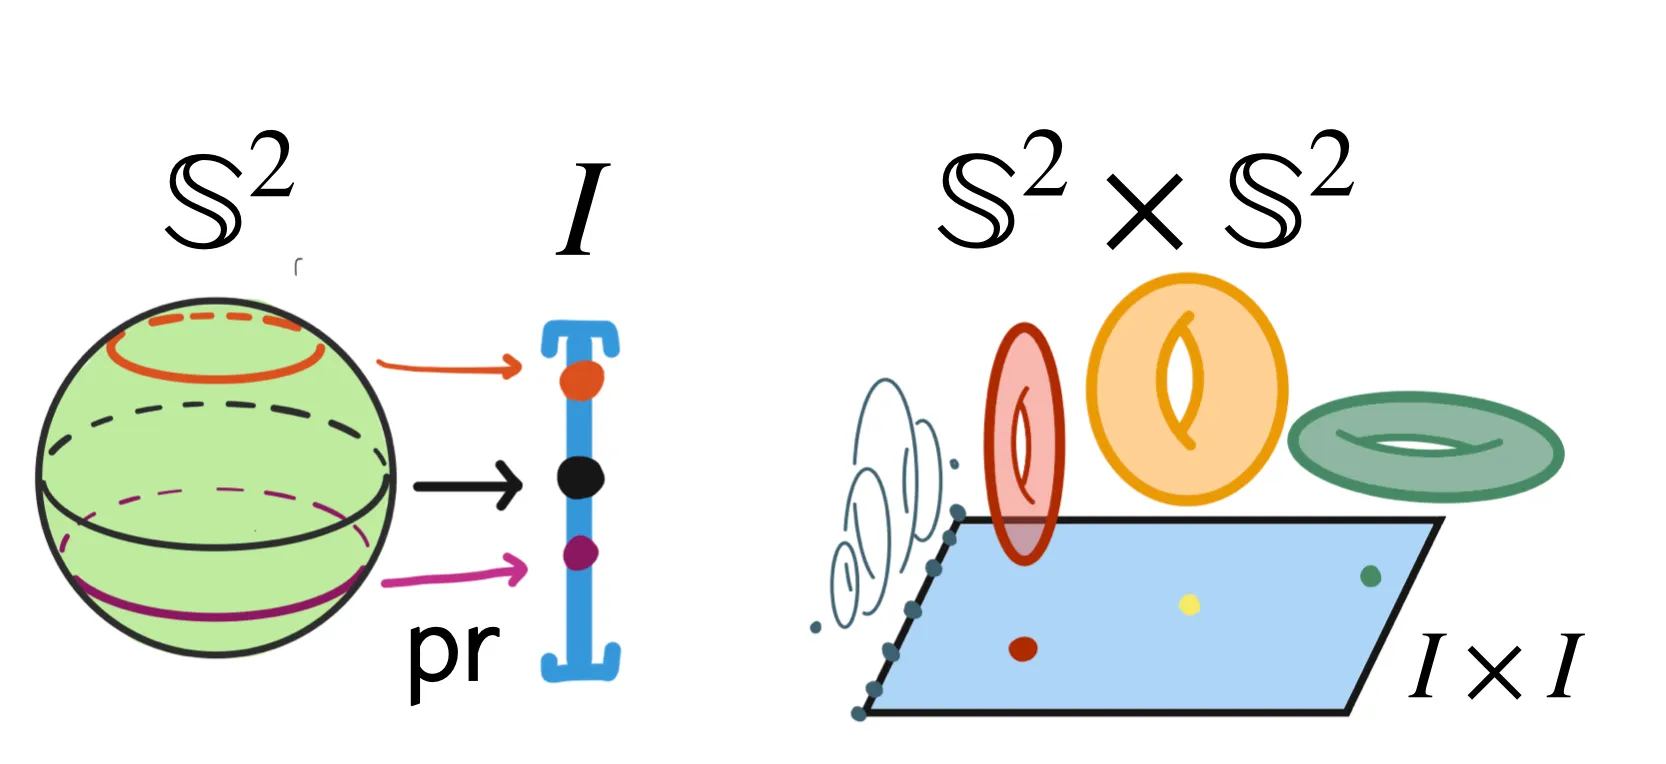
\R^3 R 3 p r : S 2 → I \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\mathsf{pr}\colon\S^2\to I pr : S 2 → I z \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
z z I = [ − 1 , 1 ] \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
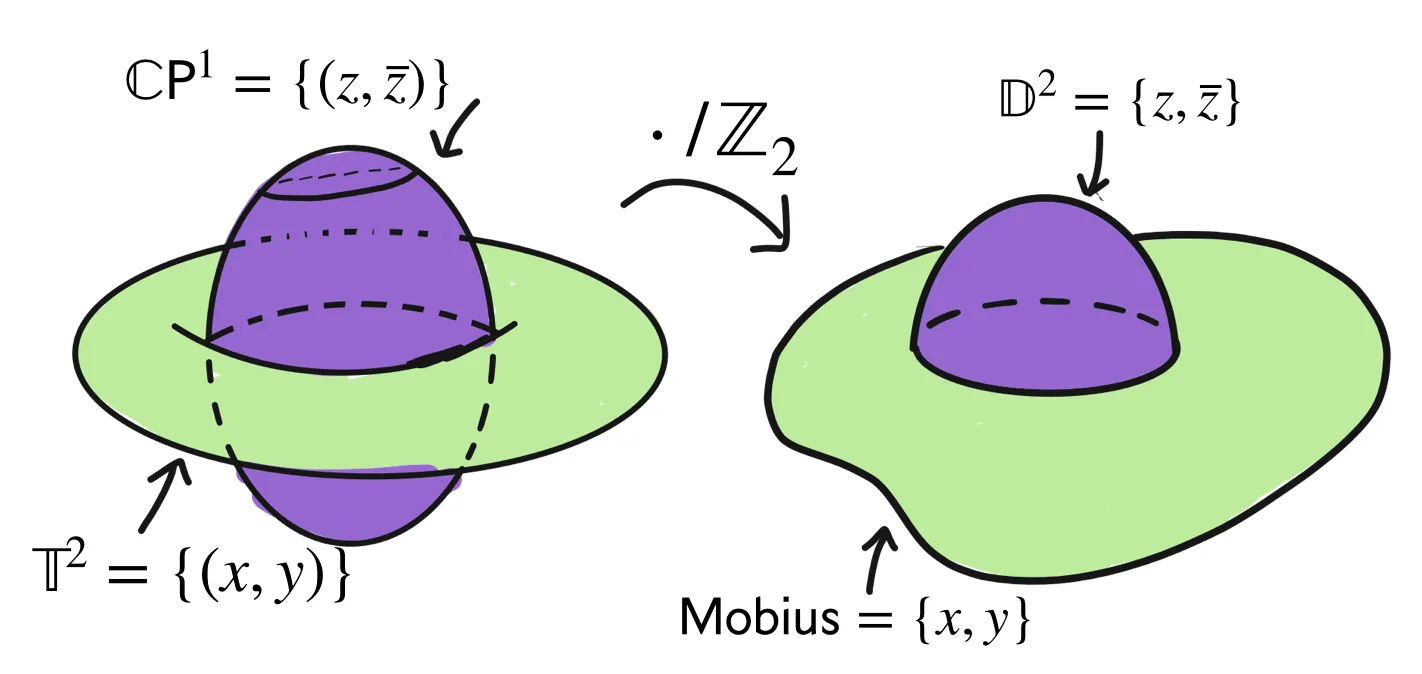
I=[-1,1] I = [ − 1 , 1 ] p r × p r : S 2 × S 2 → I × I \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\mathsf{pr}\times\mathsf{pr}\colon\S^2\times\S^2\to I\times I pr × pr : S 2 × S 2 → I × I ( x , y ) ∈ I 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
(x,y)\in I^2 ( x , y ) ∈ I 2 x \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
x x y \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
y y
S2 x S2 as a degenerate fiber bundle S 2 × S 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\S^2\times\S^2 S 2 × S 2 T 2 × I 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
T^2\times I^2 T 2 × I 2
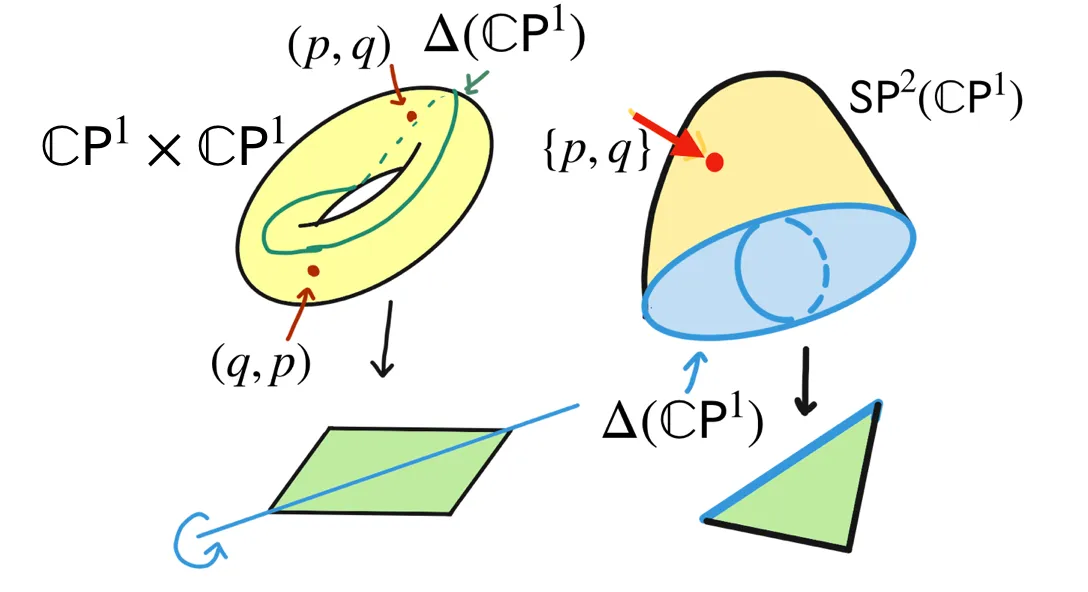
The diagonal embedding Δ : S 2 ↪ S 2 × S 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Delta\colon \S^2\hookrightarrow\S^2\times\S^2 Δ : S 2 ↪ S 2 × S 2 I × I \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
I\times I I × I Z 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Z_2 Z 2 Δ ( S 2 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Delta(\S^2) Δ ( S 2 ) S P 2 ( S 2 ) ≅ C P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\S^2)\cong\CP^2 SP 2 ( S 2 ) ≅ CP 2 S P 2 ( S 2 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\S^2) SP 2 ( S 2 ) S 2 × S 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\S^2\times\S^2 S 2 × S 2 S 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\S^2 S 2
Forming the symmetric product Forming the symmetric product S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\mathsf{SP}^2(\CP^1) SP 2 ( CP 1 ) C P 1 × C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1\times\CP^1 CP 1 × CP 1 Δ ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Delta(\CP^1) Δ ( CP 1 ) boundary of S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 )
It’s instructive to view some important subsets of polynomials in both the roots and coefficient spaces.
In the coefficients model, the at-most-linear polynomials show up as the C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1 CP 1 [ 1 : 0 : 0 ] ≃ z 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
[1:0:0]\simeq z^2 [ 1 : 0 : 0 ] ≃ z 2 C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1 CP 1 { ∞ , z } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\{\infty, z\} { ∞ , z } S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 ) C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1 CP 1 C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1 CP 1 ∞ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\infty ∞ Δ ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Delta(\CP^1) Δ ( CP 1 ) S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 )
The sphere of at most linear polynomials and the sphere of polynomials having a double root The sphere of at most linear polynomials and the sphere of polynomials having a double root meet only in the constant polynomial.
In the coefficient model this set is more difficult to spell out: it is the projective variety cut out by the discriminant V ( δ ) = V ( b 2 − 4 a c ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
V(\delta)=V(b^2-4ac) V ( δ ) = V ( b 2 − 4 a c ) b 2 − 4 a c \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
b^2-4ac b 2 − 4 a c x 2 + y 2 + z 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
x^2+y^2+z^2 x 2 + y 2 + z 2 C \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\C C z = − 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
z=-1 z = − 1 x 2 + y 2 = 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
x^2+y^2=1 x 2 + y 2 = 1 C 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\C^2 C 2
The projective variety V(b^2-4ac) The projective variety V ( b 2 − 4 a c ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
V(b^2-4ac) V ( b 2 − 4 a c ) C P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^2 CP 2 V ( x 2 + y 2 + z 2 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
V(x^2+y^2+z^2) V ( x 2 + y 2 + z 2 ) V ( x 2 + y 2 = 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
V(x^2+y^2=1) V ( x 2 + y 2 = 1 )
Next we aim to impose some notions of geometry on the space of quadratics.
The coefficient model, C P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^2 CP 2 PSL ( 3 ; C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\PSL(3;\C) PSL ( 3 ; C ) C 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\C^2 C 2 ∞ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\infty ∞ S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 ) C P 1 × C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1\times\CP^1 CP 1 × CP 1 Aut ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Aut(\CP^1) Aut ( CP 1 ) Z 2 ⋉ PSL ( 2 ; C ) × PSL ( 2 ; C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Z_2\ltimes \PSL(2;\C)\times\PSL(2;\C) Z 2 ⋉ PSL ( 2 ; C ) × PSL ( 2 ; C ) S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 ) Δ ( PSL ( 2 ; C ) ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Delta(\PSL(2;\C)) Δ ( PSL ( 2 ; C )) S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 ) C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1 CP 1 C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1 CP 1 S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 )
Automorphisms of SP^2(CP^1) Automorphisms of S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\mathsf{SP}^2(\mathbb{CP}^1) SP 2 ( CP 1 ) C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1 CP 1
Finally, it will be useful to return to the coefficients model, and compute the restricted group of symmetries which ‘play nicely’ with the roots map.
As symmetries of S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 ) C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1 CP 1 V ( δ ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
V(\delta) V ( δ ) δ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\delta δ C 3 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\C^3 C 3 C P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^2 CP 2 V ( δ ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
V(\delta) V ( δ ) PO ( δ , C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\PO(\delta,\C) PO ( δ , C ) SL ( 2 , C ) → SO ( 3 ; C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SL(2,\C)\to\SO(3;\C) SL ( 2 , C ) → SO ( 3 ; C ) SL ( 2 , C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SL(2,\C) SL ( 2 , C ) C \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\C C SO ( δ , C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SO(\delta,\C) SO ( δ , C ) SO ( 3 ; R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SO(3;\R) SO ( 3 ; R ) SO ( 2 , 1 ; R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SO(2,1;\R) SO ( 2 , 1 ; R ) SO ( δ , C ) ≅ SL ( 2 ; C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SO(\delta,\C)\cong\SL(2;\C) SO ( δ , C ) ≅ SL ( 2 ; C ) V ( δ ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
V(\delta) V ( δ ) SO ( 3 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SO(3) SO ( 3 ) SO ( 2 , 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SO(2,1) SO ( 2 , 1 ) V ( δ ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
V(\delta) V ( δ ) SO ( δ ; R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SO(\delta;\R) SO ( δ ; R )
Complex automorphisms In root space, the automorphisms of S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 ) PSL ( 2 ; C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\PSL(2;\mathbb{C}) PSL ( 2 ; C ) SO ( δ , C ) ⊂ PSL ( 3 ; C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SO(\delta,\C)\subset\PSL(3;\C) SO ( δ , C ) ⊂ PSL ( 3 ; C )
It is interesting to note that from this perspective, it is still natural to allow automorphisms mixing quadratic with linear polynomials, but no longer mixing polynomials with distinct roots with those having a double root.
Real Quadratics
If we restrict to polynomials with real coefficients, P o l ≤ 2 ( C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Pol_{\leq 2}(\C) Pol ≤ 2 ( C ) P o l ≤ 2 ( R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Pol_{\leq 2}(\R) Pol ≤ 2 ( R ) C P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^2 CP 2 R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2 R o o t s : C P 2 → S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\mathsf{Roots}\colon\CP^2\to\SP^2(\CP^1) Roots : CP 2 → SP 2 ( CP 1 ) R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2 S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 ) R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2 C P 1 × C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1\times\CP^1 CP 1 × CP 1 Δ ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Delta(\CP^1) Δ ( CP 1 )
Real quadratics come in two flavors: those with real roots, and those with complex conjugate roots.C P 1 × C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1\times\CP^1 CP 1 × CP 1 ( z , z ‾ ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
(z,\overline{z}) ( z , z ) z \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
z z C ∪ ∞ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\C\cup\infty C ∪ ∞ Δ ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Delta(\CP^1) Δ ( CP 1 ) { ( x , x ) ∣ x ∈ R ∪ ∞ } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\{(x,x)\mid x\in\R\cup\infty\} {( x , x ) ∣ x ∈ R ∪ ∞ } { ( x , y ) ∣ x , y ∈ R ∪ ∞ } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\{(x,y)\mid x,y\in\R\cup\infty\} {( x , y ) ∣ x , y ∈ R ∪ ∞ } C P 1 × C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1\times\CP^1 CP 1 × CP 1 { ( x , x ) ∣ x ∈ R ∪ ∞ } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\{(x,x)\mid x\in\R\cup \infty\} {( x , x ) ∣ x ∈ R ∪ ∞ } ( 1 , 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
(1,1) ( 1 , 1 ) C P 1 × C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1\times\CP^1 CP 1 × CP 1 R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2
Torus and sphere The preimage of the R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2 S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 ) C P 1 × C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1\times\CP^1 CP 1 × CP 1 R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2
Note that this R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2 S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 ) S 2 ∪ S 1 T 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\S^2\cup_{\S^1}T^2 S 2 ∪ S 1 T 2 S 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\S^1 S 1 R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2
Real points The real quadratic polynomials form an R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2 C P 2 ≅ S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^2\cong \SP^2(\CP^1) CP 2 ≅ SP 2 ( CP 1 ) R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2
To calculate the automorphisms of this subset in each the coefficient and roots viewpoints, we find the subgroup which fixes the real points setwise.
In the coefficient view this is easy: the smoothly embedded R P 2 ⊂ C P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2\subset\CP^2 RP 2 ⊂ CP 2 PSL ( 3 ; R ) < PSL ( 3 ; C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\PSL(3;\R)<\PSL(3;\C) PSL ( 3 ; R ) < PSL ( 3 ; C ) R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2 S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 ) Δ ( R ∪ ∞ ) ⊂ Δ ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Delta(\R\cup\infty)\subset\Delta(\CP^1) Δ ( R ∪ ∞ ) ⊂ Δ ( CP 1 ) PSL ( 2 ; R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\PSL(2;\R) PSL ( 2 ; R ) R P 2 ⊂ C P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2\subset\CP^2 RP 2 ⊂ CP 2 Aut ( R P 2 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Aut(\RP^2) Aut ( RP 2 ) Aut ( V ( δ ) ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Aut(V(\delta)) Aut ( V ( δ )) SO ( δ ; R ) = PGL ( 3 ; R ) ∩ SO ( δ ; C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SO(\delta;\R)=\PGL(3;\R)\cap\SO(\delta;\C) SO ( δ ; R ) = PGL ( 3 ; R ) ∩ SO ( δ ; C ) R \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\R R δ = b 2 − 4 a c \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\delta=b^2-4ac δ = b 2 − 4 a c ( 2 , 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
(2,1) ( 2 , 1 ) SO ( 2 , 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SO(2,1) SO ( 2 , 1 ) PGL ( 3 ; R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\PGL(3;\R) PGL ( 3 ; R ) R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2
Real automorphisms The automorphism group of real quadrics in coefficient space is all of PGL ( 3 ; R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\PGL(3;\R) PGL ( 3 ; R ) PSL ( 2 ; R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\PSL(2;\R) PSL ( 2 ; R ) SO ( δ ; R ) < PSL ( 3 ; R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SO(\delta;\R)<\PSL(3;\R) SO ( δ ; R ) < PSL ( 3 ; R )
This action of SO ( 2 , 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SO(2,1) SO ( 2 , 1 ) SL ( 2 ; R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SL(2;\R) SL ( 2 ; R ) S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 ) C P 1 × C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1\times\CP^1 CP 1 × CP 1 R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2 ( z , z ‾ ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
(z,\overline{z}) ( z , z ) z ∈ C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
z\in\CP^1 z ∈ CP 1 ( x , y ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
(x,y) ( x , y ) Aut ( C P 1 × C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Aut(\CP^1\times\CP^1) Aut ( CP 1 × CP 1 ) PSL ( 2 , C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\PSL(2,\C) PSL ( 2 , C ) Aut ( C P 1 × C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Aut(\CP^1\times\CP^1) Aut ( CP 1 × CP 1 ) A ↦ ( A , A ‾ ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
A\mapsto (A,\overline{A}) A ↦ ( A , A ) PSL ( 2 ; R ) × PSL ( 2 ; R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\PSL(2;\R)\times\PSL(2;\R) PSL ( 2 ; R ) × PSL ( 2 ; R )
Torus and sphere automorphisms Automorphisms of the branched cover of R P R o o t s 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2_\mathsf{Roots} RP Roots 2 C P 1 × C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1\times\CP^1 CP 1 × CP 1
Most of the automorphisms of either component individually do not descend to the quotient S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 ) S 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\S^1 S 1 C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1 CP 1 PSL ( 2 ; R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\PSL(2;\R) PSL ( 2 ; R ) C \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\C C C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1 CP 1 3 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
3 3 PSL ( 2 , C ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\PSL(2,\C) PSL ( 2 , C ) H 3 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\mathbb{H}^3 H 3 A d S 3 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\mathsf{AdS}^3 AdS 3 PSL ( 2 ; R ) × PSL ( 2 ; R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\PSL(2;\R)\times\PSL(2;\R) PSL ( 2 ; R ) × PSL ( 2 ; R ) A d S 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\mathsf{AdS}^2 AdS 2 PSL ( 2 ; R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\PSL(2;\R) PSL ( 2 ; R ) R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2 S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 )
Torus sphere quotient The R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2
We’ve done all the hard work now; having described the domain and codomain of the roots map assigning coefficients in C P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^2 CP 2 S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 )
The map taking coefficients to roots, when restricted to real quadratics with complex roots, is an isometry from the projective model H 2 ⊂ R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Hyp^2\subset\RP^2 H 2 ⊂ RP 2 H 2 ⊂ C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Hyp^2\subset \CP^1 H 2 ⊂ CP 1
The complex roots of a real quadratic come in conjugate pairs, and so are represented in root space by the disk { z , z ‾ } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\{z,\overline{z}\} { z , z } S P 2 ( C P 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SP^2(\CP^1) SP 2 ( CP 1 ) ¶ { δ < 0 } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\P\{\delta<0\} ¶ { δ < 0 } R P 2 ⊂ C P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2\subset\CP^2 RP 2 ⊂ CP 2 C P 1 × C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1\times\CP^1 CP 1 × CP 1 C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1 CP 1 SO ( δ , R ) ≅ SO ( 2 , 1 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SO(\delta,\R)\cong\SO(2,1) SO ( δ , R ) ≅ SO ( 2 , 1 ) R o o t s : D C o e f s 2 → D R o o t s 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots\colon \D_\mathsf{Coefs}^2\to\D_{\mathsf{Roots}}^2 Roots : D Coefs 2 → D Roots 2 g ∈ Isom ( H 2 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
g\in\Isom(\mathbb{H}^2) g ∈ Isom ( H 2 ) R o o t s ( g . f ) = g . R o o t s ( f ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots(g.f)=g.\Roots(f) Roots ( g . f ) = g . Roots ( f ) g \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
g g SO ( δ ; R ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\SO(\delta;\R) SO ( δ ; R ) Δ ( PSL ( 2 ; R ) ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Delta(\PSL(2;\R)) Δ ( PSL ( 2 ; R ))
Root isometry The roots map is an intertwiner for the action of isometries on both sides, and is itself an isometry from the coefficients model to the roots model.
It only remains to show that R o o t s \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots Roots R o o t s \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots Roots Isom ( H 2 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Isom(\Hyp^2) Isom ( H 2 ) R o o t s \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots Roots f = z 2 + 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
f=z^2+1 f = z 2 + 1 R o o t s ( f ) = { i , − i } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots(f)=\{i,-i\} Roots ( f ) = { i , − i } Φ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Phi Φ Φ ( z 2 + 1 ) = { i , − i } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Phi(z^2+1)=\{i,-i\} Φ ( z 2 + 1 ) = { i , − i } R o o t s , Φ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots, \Phi Roots , Φ Isom ( H 2 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Isom(\Hyp^2) Isom ( H 2 ) D C o e f s 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\D^2_{\mathsf{Coefs}} D Coefs 2 D R o o t s 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\D^2_{\mathsf{Roots}} D Roots 2 z 2 + 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
z^2+1 z 2 + 1
To finish it off, we will write this map down in coordinates, as an explicit map from a disk in R P 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\RP^2 RP 2 C P 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\CP^1 CP 1 f = a z 2 + b z + c \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
f=az^2+bz+c f = a z 2 + b z + c [ a : b : c ] \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
[a:b:c] [ a : b : c ] R o o t s : [ a : b : c ] ↦ { − b ± b 2 − 4 a c 2 a } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots:[a:b:c]\mapsto \left\{ \frac{-b\pm\sqrt{b^2-4ac}}{2a}\right\} Roots : [ a : b : c ] ↦ { 2 a − b ± b 2 − 4 a c }
To get useful coordinates on the codomain, note that as the roots are always a complex conjugate pair, one must be in the upper half plane and the other in the lower.
Thus we may unambiguously select the root in the upper half plane and represent our pair of roots by a single number x + i y \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
x+iy x + i y y > 0 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
y>0 y > 0 δ < 0 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\delta<0 δ < 0 − \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\sqrt{-} − R o o t s : [ a : b : c ] ↦ − b 2 a + i 4 a c − b 2 2 a \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots\colon[a:b:c]\mapsto \frac{-b}{2a}+i\frac{\sqrt{4ac-b^2}}{2a} Roots : [ a : b : c ] ↦ 2 a − b + i 2 a 4 a c − b 2 a = 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
a=1 a = 1 R 2 = { ( b , c ) } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\R^2=\{(b,c)\} R 2 = {( b , c )} b 2 < 4 c \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
b^2<4c b 2 < 4 c
R o o t s : ( b , c ) ↦ − b 2 + i 4 c − b 2 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots\colon (b,c)\mapsto \frac{-b}{2}+i\frac{\sqrt{4c-b^2}}{2} Roots : ( b , c ) ↦ 2 − b + i 2 4 c − b 2
Parabola model The quadratic formula as usually written is a map from a projective model of H 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\mathbb{H}^2 H 2
This is nothing more than the quadratic formula as learned in grade school, but we know from the above that we may interpret this as an isometry between two copies of the hyperbolic plane!
The copy in the codomain is familiar; by selecting coordinates given by the root with positive imaginary part we have naturally landed in the upper half plane.
But what is the model in the domain?
This ‘paraboloid’ model is in fact the Klein model in disguise - we have just chosen the wrong affine patch; one that runs parallel to the lightcone instead of transverse to it.
Slicing cones projective model of the hyperbolic plane is a paraboloid, hyperboloid disk depending on choice of affine patch.
To reconstruct the more familiar picture, we need to change the affine patch.
The following transformation does the job:
( a b c ) = ( w + u 2 v w − u 2 ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\pmat{
a\\b\\c
}=
\pmat{
\tfrac{w+u}{2}\\v\\\frac{w-u}{2}
} a b c = 2 w + u v 2 w − u In these coordinates, the discriminant is δ = u 2 + v 2 − w 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\delta=u^2+v^2-w^2 δ = u 2 + v 2 − w 2 ( w + u ) z 2 + 2 v z + ( w − u ) = 0 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
(w+u)z^2+2vz+(w-u)=0 ( w + u ) z 2 + 2 v z + ( w − u ) = 0
R o o t s : [ u : v : w ] ↦ − v u + w + i w 2 − u 2 − v 2 u + w \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots\colon [u:v:w]\mapsto\frac{-v}{u+w}+i\frac{\sqrt{w^2-u^2-v^2}}{u+w} Roots : [ u : v : w ] ↦ u + w − v + i u + w w 2 − u 2 − v 2
The disk D C o e f s 2 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\D^2_\mathsf{Coefs} D Coefs 2 w = 1 \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
w=1 w = 1 0 ⃗ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\vec{0} 0 R 2 = { ( u , v ) } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\R^2=\{(u,v)\} R 2 = {( u , v )} { ( u , v ) ∣ u 2 + v 2 < 1 } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\{(u,v)\mid u^2+v^2<1\} {( u , v ) ∣ u 2 + v 2 < 1 } { z ∣ I m ( z ) > 0 } \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\{z\mid \mathsf{Im}(z)>0\} { z ∣ Im ( z ) > 0 }
R o o t s : ( u , v ) ↦ − v 1 + u + i 1 − u 2 − v 2 1 + u \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\Roots\colon (u,v)\mapsto \frac{-v}{1+u}+i\frac{\sqrt{1-u^2-v^2}}{1+u} Roots : ( u , v ) ↦ 1 + u − v + i 1 + u 1 − u 2 − v 2
Klein disk to upper half plane After a linear change of coordinates, the quadratic formula provides the usual identification of the Klein model with the upper half plane model of hyperbolic space.
Appendix
Here’s the easy lemma that was used in the proof: an equivariant map between two spaces each equipped with a transitive G \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
G G
Let G \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
G G X , Y \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
X,Y X , Y G \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
G G f , ϕ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
f,\phi f , ϕ f ( g . x ) = g . f ( x ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
f(g.x)=g.f(x) f ( g . x ) = g . f ( x ) g , x \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
g,x g , x ϕ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\phi ϕ x \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
x x f ( x ) = ϕ ( x ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
f(x)=\phi(x) f ( x ) = ϕ ( x ) f = ϕ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
f=\phi f = ϕ
Denote f ( x ) = ϕ ( x ) = y \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
f(x)=\phi(x)=y f ( x ) = ϕ ( x ) = y z ∈ X \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
z\in X z ∈ X g ∈ G \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
g\in G g ∈ G z = g . x \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
z=g.x z = g . x f , ϕ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
f, \phi f , ϕ z \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
z z f ( z ) = f ( g . x ) = g . f ( x ) = g . y \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
f(z)=f(g.x)=g.f(x)=g.y f ( z ) = f ( g . x ) = g . f ( x ) = g . y ϕ ( z ) = ϕ ( g . x ) = g . ϕ ( x ) = g . y \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
\phi(z)=\phi(g.x)=g.\phi(x)=g.y ϕ ( z ) = ϕ ( g . x ) = g . ϕ ( x ) = g . y f ( z ) = ϕ ( z ) \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
f(z)=\phi(z) f ( z ) = ϕ ( z ) f = ϕ \providecommand{\Roots}{\mathsf{Roots}}
\providecommand{\Pol}{\mathsf{Pol}}
\providecommand{\SP}{\mathsf{SP}}
\providecommand{\Coefs}{\mathsf{Coefs}}
\providecommand{\C}{\mathbb{C}}
\providecommand{\R}{\mathbb{R}}
\providecommand{\Aut}{\operatorname{Aut}}
\providecommand{\SO}{\operatorname{SO}}
\providecommand{\CP}{\mathbb{C}\mathsf{P}}
\providecommand{\Z}{\mathbb{Z}}
\providecommand{\SL}{\operatorname{SL}}
\providecommand{\PSL}{\operatorname{PSL}}
\providecommand{\RP}{\mathbb{R}\mathsf{P}}
\providecommand{\PGL}{\operatorname{PGL}}
\providecommand{\PO}{\operatorname{PO}}
\providecommand{\D}{\mathbb{D}}
\providecommand{\Hyp}{\mathbb{H}}
\providecommand{\Isom}{\operatorname{Isom}}
\providecommand{\pmat}[1]{\begin{pmatrix}#1\end{pmatrix}}
\renewcommand{\S}{\mathbb{S}}
f=\phi f = ϕ